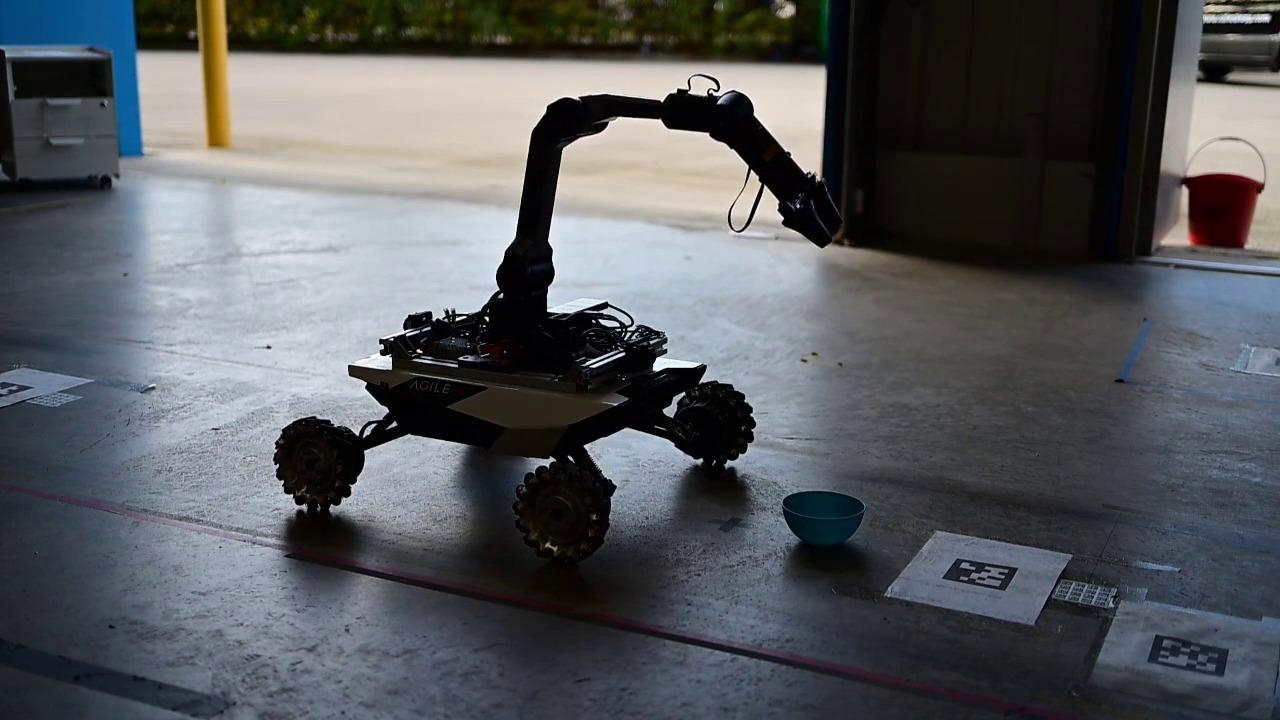
Software that makes robots deployable in the real world
Learn new places and skills quickly, on the robot - built for the reliability real work demands.

Show it once. It learns as you do.
Learn a new place in one drive.
Learn a physical skill from a handful of demonstrations.


Navigation without adapting your site
With Opteran Mind on the robot, drive the route once and start using it. It learns the route and builds its map at the same time as you drive, and keeps its understanding current as the site changes.
No infrastructure: No markers, reflectors or other site modifications. Indoors or out.
No network dependency: Runs on the robot’s existing compute. No cloud or dedicated network required.
Handle objects and decide what to do next
Teach a physical skill with a handful of demonstrations. Set goals and priorities to guide what the robot does next.